
Key facts
- Brand
- Omron
- Model
- E3S-C
- Category
- Automation control Equipment
- Industry
- Industrial
- Documents
- 2
- Languages
- EN · ZH
- Last added
- 2012-05-08
Start here
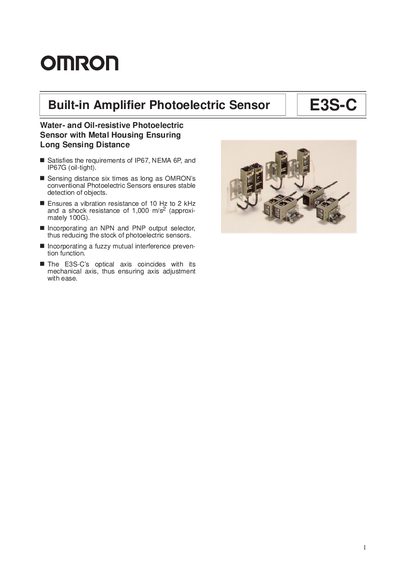
Omron E3S-C Photoelectric Sensor Manual
The E3S‑C is a water‑ and oil‑resistive photoelectric sensor with a metal housing, offering long sensing distances (up to 30 m for through‑beam models) and IP67/NEMA 6P enclosure ratings. It features selectable NPN or PNP open‑collector outputs, Light‑ON/Dark‑ON modes, and vibration resistance up to 2 kHz.
The manual includes ordering information, detailed specifications, wiring and mounting instructions, a conversion table for legacy E3S models, and dimensional drawings. It also describes output circuit operation and environmental limits such as temperature, humidity, and shock resistance.
Omron E3S-C specifications
| Sensing distance (Through‑beam) | 30 m |
|---|---|
| Power supply voltage | 10 to 30 VDC |
| Output configuration | NPN or PNP selectable, open‑collector |
| Weight (horizontal model) | 110 g (with 2‑mm cord) |
| Weight (vertical model) | 115 g (with 2‑mm cord) |
| Ambient temperature range | -25 °C to 55 °C |
| Enclosure rating | IP67, NEMA 6P |
| Vibration resistance | 10 to 2 000 Hz, approx. 30 G |
| Shock resistance | approx. 100 G |
All Omron E3S-C documents by type
Day-to-day operation, settings and troubleshooting. Start here if the product is already set up.
Questions answered in these manuals
What is the power supply voltage range for the E3S‑C sensor?
The sensor operates from 10 to 30 VDC.
How can the output type (NPN or PNP) be selected?
Use the NPN and PNP output selector on the operation panel to choose the output transistor type.
What is the recommended distance between the sensor and the reflector?
The sensor should be set at a distance greater than the minimum value specified for the chosen reflector; the exact minimum is listed in the table for each reflector model.
How does the sensor prevent interference when multiple photoelectric sensors are used together?
It uses a fuzzy‑interference‑prevention function that monitors interfering light and waits for the interference to subside before projecting, reducing false triggers.