
This manual provides installation, wiring, operation, and EtherCAT communication configuration instructions for the RS EtherCAT Series Servo V3.1 drive.
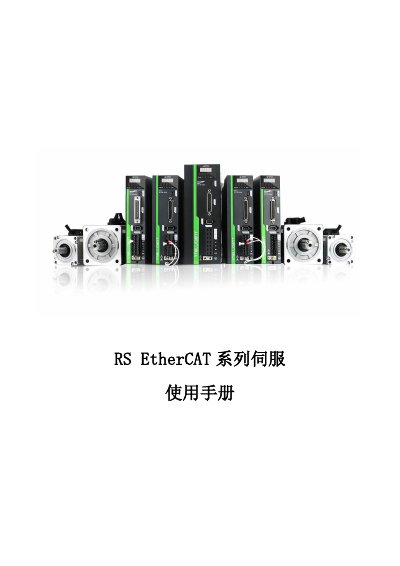
This manual is a comprehensive user guide for the RS EtherCAT Series Servo V3.1 drive, covering product information, installation, wiring, operation, and communication network configuration. It details the drive's specifications, including power ranges from 0.05 to 3KW and support for RS485 MODBUS and EtherCAT protocols. This manual is written in Chinese.
| Power Range | 0.05 ~ 3KW |
|---|---|
| Control Modes | Position, Speed, Torque |
| Encoder Support | 17 ~ 23 bit absolute |
| Operating Temperature | 0 ~ 55°C |
The power range is from 0.05 to 3KW.
The system is configured with 17 to 23-bit single/multi-turn absolute value encoders.