
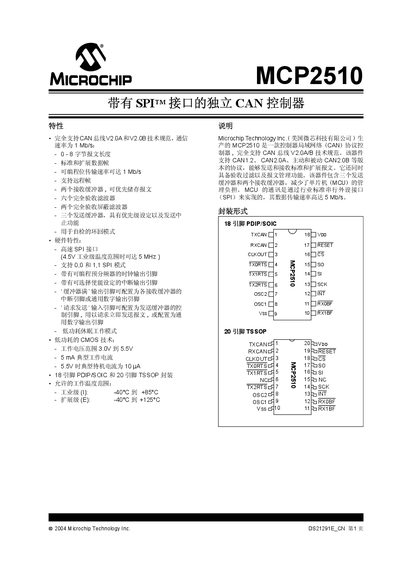
The MCP2510 is a stand‑alone CAN controller designed to simplify CAN‑bus connections. It integrates a CAN protocol engine, configuration logic with SRAM registers, and a high‑speed SPI module for communication with a host MCU.
The device operates from 3.0 V to 5.5 V, draws about 5 mA in active mode and 10 µA in standby, and is available in 18‑pin PDIP/SOIC and 20‑pin TSSOP packages. It supports CAN 2.0A/B at 1 Mb/s, offers three transmit buffers, two receive buffers, six acceptance filters, and a low‑power sleep mode. This manual is written in Chinese.
| Operating voltage range | 3.0 V to 5.5 V |
|---|---|
| Typical active current | 5 mA |
| Typical standby current | 10 µA |
| Maximum SPI clock speed | 5 MHz |
| CAN bus speed support | up to 1 Mb/s |
| Transmit buffers | 3 |
| Receive buffers | 2 |
| Package types | 18‑pin PDIP/SOIC, 20‑pin TSSOP |
It uses a high‑speed SPI interface for communication with a host microcontroller.
The MCP2510 supports CAN bus speeds up to 1 Mb/s in accordance with CAN 2.0A/B specifications.
Yes, it includes a low‑power sleep mode for reduced power consumption.