This application note describes a CAN/USB protocol converter built around the Mitsubishi M16C/6N microcontroller, covering hardware and software design.
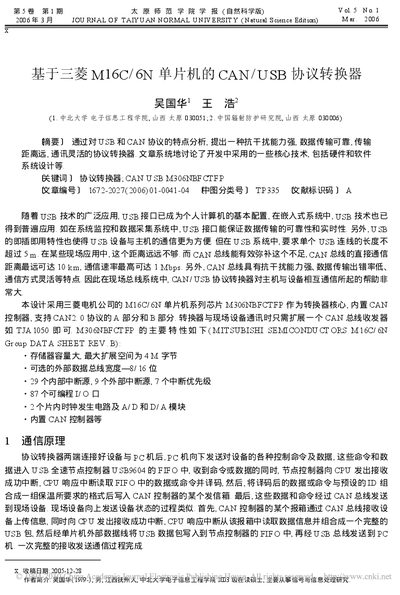
The document presents a protocol converter that bridges CAN and USB interfaces using the Mitsubishi M16C/6N microcontroller. It explains the need for reliable, anti‑interference data transfer and long‑distance communication in embedded systems.
Hardware implementation uses the M306NBFCTFP MCU, a USB9604 full‑speed USB controller, and supporting circuitry such as UART‑to‑RS232 (MAX232A). Software design includes firmware modules for USB enumeration, endpoint handling, and CAN message processing, with a PC side application for configuration and monitoring. This manual is written in Chinese.
| Built‑in CAN controller | Yes |
|---|---|
| USB controller | National Semiconductor USB9604 |
The CAN bus can directly communicate up to about 10 km.
The CAN bus can operate at up to 1 Mbps.