
Installation manual for the DFRobot Devastator Tank Mobile Platform tracked robot chassis, covering assembly steps, features and the parts list.
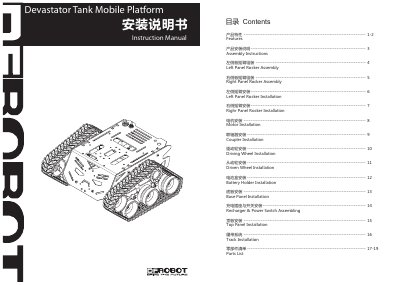
The Devastator Tank Mobile Platform is a tracked robot experimental platform developed by DFRobot. It works with popular controllers such as Arduino and Raspberry Pi, and its high-strength aluminum alloy body, high-speed motors, plastic tracks and suspension system let it climb obstacles and handle irregular terrain. Multiple mounting holes accept sensors, servos, turntables and controller boards such as the Romeo all-in-one controller, making it suitable for hobby, educational, competition and research projects.
This bilingual Chinese/English manual lists the product features and dimensions, then walks through the full assembly: left and right panel rocker assembly and installation, motor, coupler, driving and driven wheels, battery holder, base panel, charging socket and power switch, top panel and tracks, ending with a parts list. Six AA batteries, a main controller and a motor controller are not included and must be supplied by the user, along with needle-nose pliers. This manual is written in Chinese.
| Total weight | 780 g |
|---|---|
| Driving wheel diameter | 43 mm |
| Max. speed | 36 cm/s |
| Dimensions | 225 mm × 220 mm × 108 mm / 103 mm |
| Motor input voltage | 3–8 V DC |
| Motor gear ratio | 1:120 |
| No-load speed (6V) | 180 RPM |
| No-load current (6V) | 160 mA |
| Stall current (6V) | 2.8 A |
It is compatible with popular controllers such as Arduino and Raspberry Pi, and its mounting holes also fit boards like the Romeo all-in-one controller.
Six AA batteries, the main controller and the motor controller are not included and must be supplied by the user.
You need needle-nose pliers, and the parts list should be referred to during installation.
The maximum driving speed is 36 cm/s.