
MCP2510 is a Full Controller Area Network (CAN) protocol controller implementing CAN specification V2.0 A/B. It supports CAN 1.2, CAN 2.0A, CAN 2.0B Passive, and CAN 2.0B Active versions of the protocol, and is capable of transmitting and receiving standard and extended data frames.
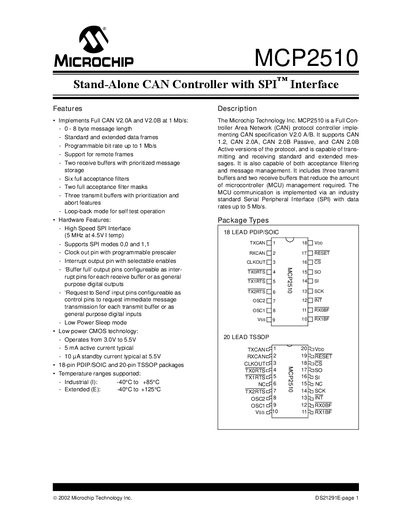
The MCP2510 is a stand‑alone CAN controller that provides a full CAN 2.0A/B protocol implementation with an SPI interface for easy integration into microcontroller‑based systems. It includes three transmit buffers, two receive buffers, acceptance filters, and a low‑power sleep mode.
The document covers device functionality, CAN message frame formats, bit timing, error detection, interrupt handling, electrical characteristics, packaging options, and register maps, providing all the information needed for hardware designers and firmware developers.
| Operating Voltage | 3.0 V to 5.5 V |
|---|---|
| Active Current | 5 mA typical |
| Standby Current | 10 µA typical at 5.5 V |
| Package Types | 18‑pin PDIP/SOIC and 20‑pin TSSOP |
| Temperature Range | Industrial: –40 °C to +85 °C; Extended: –40 °C to +125 °C |
| SPI Interface Speed | 5 MHz at 4.5 V |
| Supported SPI Modes | 0,0 and 1,1 |
| Sleep Mode | Low Power Sleep mode |
The MCP2510 operates from 3.0 V to 5.5 V.
It provides three transmit buffers and two receive buffers.
Industrial range –40 °C to +85 °C and extended range –40 °C to +125 °C.