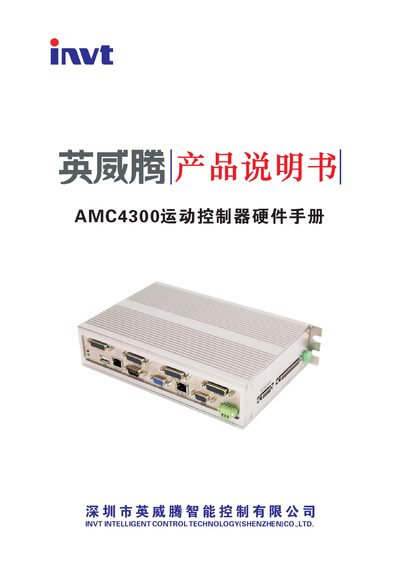
The INVT AMC4300 motion controller hardware manual provides an overview, specifications, control modes, interface definitions, and driver wiring instructions.
About this manual
The AMC4300 is a motion‑control platform that uses a Cortex‑A8 processor, a real‑time Linux OS and FPGA hardware to control up to 4, 8, or 16/32 axes via EtherCAT, RS‑232/485/422, USB and other interfaces. It supports standalone (Alone) operation with a VGA display as well as A+PC networking modes, and includes built‑in PID/FF control for precise motion.
The manual details the controller's hardware resources, connector pinouts, GPIO and ARIO boards, and provides wiring diagrams and parameter settings for a wide range of servo drives from INVT, Delta, Yaskawa and other manufacturers. An appendix describes system firmware updates and SD‑card replacement procedures. This manual is written in Chinese.
What's inside
- Overview
- Control Modes
- Installation and Use
- Hardware Description
- Driver Wiring and Parameter Settings
- Appendix
Specifications
| CPU | Cortex‑A8 32‑bit 1 GHz |
|---|
| Flash Memory | 2 GB |
|---|
| DDR Memory | 512 MB |
|---|
| Ethernet Interface | EtherCAT bus |
|---|
| Supported Axes | 4, 8, 16 or 32 |
|---|
| Maximum Pulse Frequency | 4 MHz |
|---|
| ADC Channels | 4 × 14‑bit |
|---|
| DAC Channels | 4 × 16‑bit |
|---|
| Encoder Interface | 4 × 32‑bit |
|---|
| RS‑485 Ports | 1 set |
|---|
| RS‑232 Ports | 3 sets |
|---|
Frequently asked questions
What control modes are available for the AMC4300?
The controller supports an Alone (AMC+VGA) standalone mode and an A+PC networking mode.
How many axes can the AMC4300 control?
Depending on the model, it can control 4, 8, or 16/32 axes.