
This document introduces two products of TRINAMIC Motion Control GmbH & Co. KG, PDx-113-57/60-SE and TMCM-113-60-SE, including maximum current and voltage supported, supported communication protocols, encoder type, stallGuard™ function, etc.
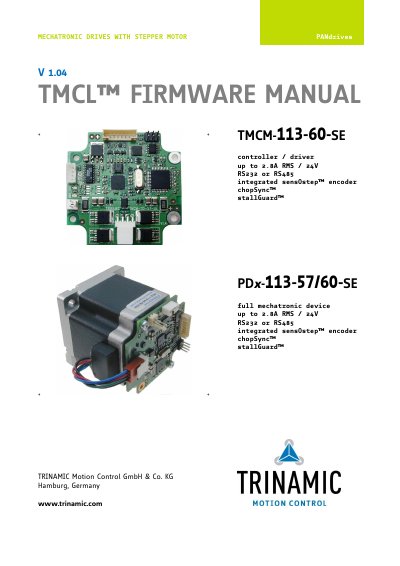
This document is the firmware manual for the TRINAMIC PDx-113-57/60-SE and TMCM-113-60-SE, which are full mechatronic devices combining a stepper motor, controller, and driver. The manual details the TMCL (TRINAMIC Command Language) firmware version 1.04, explaining how to put the device into operation, write simple programs using the TMCL-IDE, and operate the module in direct mode.
| Supply voltage | +24V DC nominal (+7V… +28.5V DC) |
|---|---|
| Motor current | up to 2.8A RMS (programmable) |
| Holding torque (57mm motor) | 0.55Nm, 1.01Nm, 1.26Nm or 1.89Nm |
| Holding torque (60mm motor) | 1.1Nm, 1.65Nm, 2.1Nm or 3.1Nm |
| Encoder increments | max. 256 increments per rotation |
| Program memory | up to 2048 TMCL commands |
The nominal supply voltage is +24V DC.
Yes, the motor current is programmable up to 2.8A RMS.
The device can store up to 2048 TMCL commands in non-volatile memory.
The holding torque options are 0.55Nm, 1.01Nm, 1.26Nm, or 1.89Nm.