
This document provides the hardware manual and functional description of the TMCM-343 3-axis stepper controller/driver module by Trinamic Motion Control GmbH & Co. KG. The module has a nominal supply voltage range of 8V to 34V DC and supports a current range of 300mA to 1.1A RMS. The module supports TMCL™/CANopen firmware and various communication interfaces including CAN 2.0b, RS232, and RS485. Additionally, the module features stallGuard™ sensorless motor stall detection, reference switches, and other input/output functionalities.
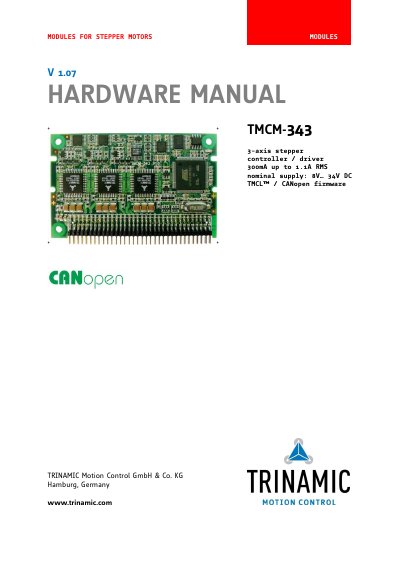
The TMCM-343 is a compact and versatile triple axis 2-phase stepper motor controller and driver module designed for embedded applications. It provides a complete motion control solution at a very small size, featuring integrated additional I/Os for complete system control applications. The module supports both stand-alone operation using the TMCL™ language and remote controlled operation via PC.
| Axis count | 3-axis |
|---|---|
| Coil current | 300mA to 1.1A RMS |
| Supply voltage | 8V to 34V DC |
| Peak current | 1.5A |
| Microstepping | Up to 64 times |
| EEPROM storage | 16 KByte |
| Dimensions | 80 x 50 x 8 mm |
The nominal supply voltage ranges from 8V to 34V DC.
Yes, it includes the optional stallGuard™ feature for sensorless motor stall detection.
Host communication is possible via the serial UART interface (RS232 or RS485) or via CAN.