
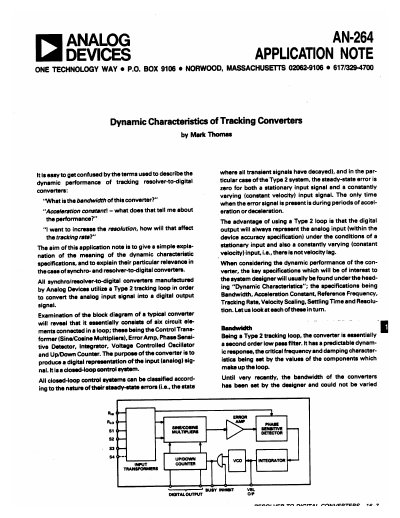
The document provides a simple explanation of terms used to describe the dynamic performance of tracking resolver-to-digital converters. It details how these converters utilize a Type 2 tracking loop to convert analog input signals into digital output signals with zero steady-state error under stationary and constant velocity conditions.
Key specifications discussed include Bandwidth, Acceleration Constant (Ks), Reference Frequency, Tracking Rate, Velocity Scaling, Settling Time, and Resolution. The text explains the relationship between these parameters, noting that higher bandwidth allows for faster response but increases susceptibility to noise, while resolution affects both tracking rate and settling time.
| Output Resolution Options | 10-, 12-, 14- or 16-bit output resolution |
|---|---|
| Minimum Reference Frequency | 2.5 times the closed-loop bandwidth |
The steady-state error is zero for both a stationary input signal and a constantly varying (constant velocity) input signal.
Increasing the resolution from N to N +2 bits will lead to a factor of 4 decrease in the tracking rate.