
UIM2501 is a CAN/RS232 step motor conversion controller that can be used to control UIM242xx type CAN series step motor driver. The controller adopts high-performance DSP embedded microprocessor system, with rich control instructions, supports online control or offline programming execution, and is easy to use.
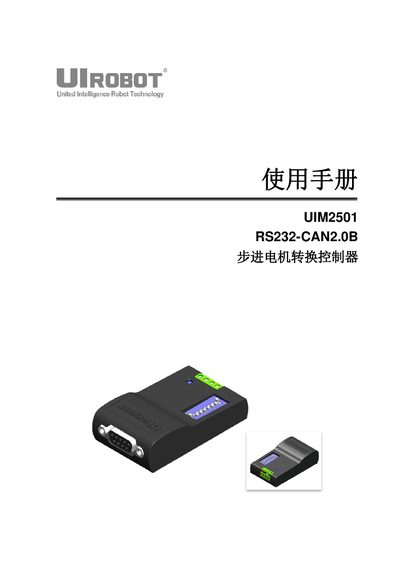
This manual provides an overview of the UIM2501 controller, a compact RS232/CAN2.0B converter designed to work with UI Robot UIM242xx step‑motor drivers. It describes the hardware layout, wiring ports, DIP‑switch settings, and typical wiring diagrams for both single‑device and network configurations.
The document also details the communication features (RS232 up to 115200 bps, CAN2.0B up to 1 Mbps), performance specifications, and a full set of global commands for controlling multiple drivers on a CAN bus. Installation, command syntax, and troubleshooting information are included to help users integrate the controller into industrial automation or robotic systems. This manual is written in Chinese.
| Supply voltage | 6 V – 40 VDC |
|---|---|
| RS232 max baud rate | 115200 bps |
| CAN2.0B max bitrate | 1 Mbps |
| Maximum CAN nodes | 100 |
| Storage temperature | -50 °C – 150 °C |
| Dimensions | 66.4 mm × 38 mm × 18 mm |
| Weight | 0.1 kg |
| Input current | 100 mA |
| RS232 RX voltage range | -25 V to +25 V |
| RS232 TX voltage range | -13.2 V to +13.2 V |
Up to 100 driver nodes can be connected to the CAN bus.
The RS232 interface can operate up to 115200 bps.