
Key facts
- Brand
- AutoChips
- Model
- AC781x
- Category
- Motor
- Industry
- Industrial
- Documents
- 3
- Languages
- EN · ZH
- Last added
- 2026-11-06
Start here
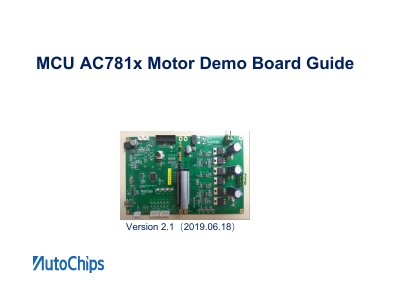
Autochips AC781x Motor Demo Board Guide
The Autochips AC781x Motor Demo Board is a development tool designed for testing and debugging Brushless Direct Current (BLDC) and Permanent Magnet Synchronous Motor (PMSM) applications. The board consists of two main sections: an MCU control board and a power drive board, connected via a 34-pin IDC cable. The MCU control board provides debugging interfaces (JTAG), communication ports (CAN, LIN, UART, SPI), and inputs for motor sensors (Hall effect and encoders). The power drive board handles the motor drive signals and power supply, supporting input voltages from 12V to 48V.
Read onlineAutochips AC781x specifications
| Operating Voltage | 2.7 to 5.5 V |
|---|---|
| Operating Temperature | -40 to 125°C |
| Core | ARM® Cortex-M3 |
| Flash Memory | Up to 256 KB |
| RAM | Up to 64 KB |
| Package Options | 80-pin LQFP, 64-pin LQFP |
| Supply Current | Max 60 mA |
| Storage Temperature | -55 to 150°C |
| ESD Voltage (HBM) | -8000 to 8000 V |
| ESD Voltage (CDM) | -750 to 750 V |
All Autochips AC781x documents by type
Ratings, dimensions and ordering codes, for selection and design work.
Day-to-day operation, settings and troubleshooting. Start here if the product is already set up.
Questions answered in these manuals
What is the operating voltage range for the AC781x?
The operating voltage range is 2.7 to 5.5 V.
What is the maximum operating temperature?
The maximum operating temperature is 125°C.
What is the operating voltage range of the AC781x?
The device operates from 2.7 V up to 5.5 V.
What temperature range can the AC781x operate in?
It is rated for -40 °C to 125 °C ambient temperature.
What motor types does the AC781x Motor Demo Board support?
The board supports development and debugging of BLDC (Brushless Direct Current Motor) and PMSM (Permanent Magnet Synchronous Motor).
How is the drive mode selected on the board?
Drive modes are selected using three jumpers: JP1, JP2, and JP3, which configure GPIO levels for Hall sensor presence and control algorithm selection.