
This document introduces the use of CYCLOPS OSD V4.0 flight display, mainly including hardware introduction, wiring instructions, use instructions, display instructions and precautions.
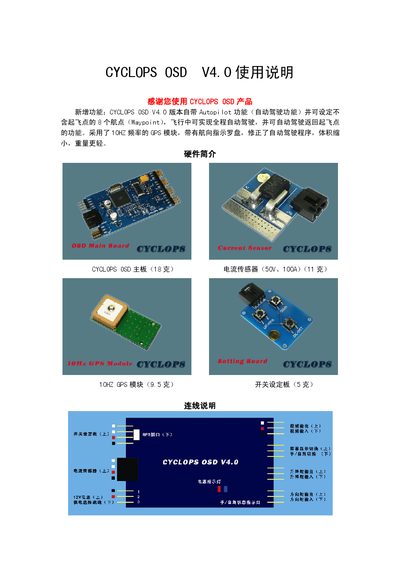
This guide introduces the CYCLOPS OSD V4.0 flight controller, its lightweight hardware (18 g main board, 10 Hz GPS module, current sensor, and switch board) and the new Autopilot function that can fly up to eight way‑points and return to the launch point automatically. It also explains the LED status indicators and the basic wiring connections.
The manual details how to power on the device, navigate the menu with the up/down keys, configure display options, reset the current sensor, and set autopilot parameters such as waypoint distance, heading correction limits, and cruise altitude. Safety notes, recommended model aircraft, and fail‑safe settings for loss of GPS signal are also covered. This manual is written in Chinese.
| Main board weight | 18 g |
|---|---|
| Current sensor rating | 50 V, 100 A |
| Current sensor weight | 11 g |
| GPS module frequency | 10 Hz |
| GPS module weight | 9.5 g |
| Switch board weight | 5 g |
| Autopilot status LED | Blue LED flashes when autopilot is active |