
This is the product manual for TMCM-1630 1-Axis BLDC Controller/Driver. It includes features, overview, usage and command introductions.
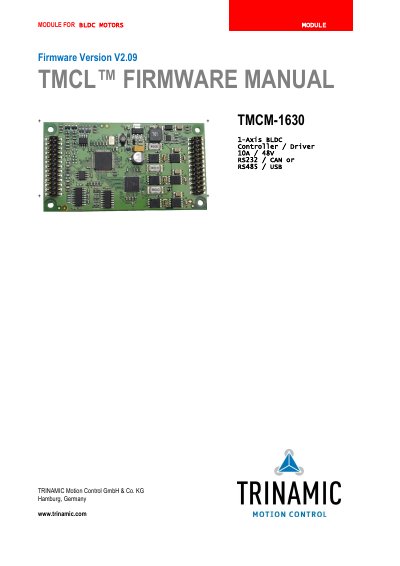
This document provides detailed instructions for operating and programming the Trinamic TMCM-1630 1-axis BLDC controller. It covers firmware updates, interface connections, motor setup, and TMCL command syntax. The controller integrates a high-performance ARM Cortex-M3 microcontroller and pre-driver for BLDC motor control, supporting both standalone and remote operation. It includes sections on motion commands, parameter settings, I/O ports, and motor regulation modes.
The manual also includes safety precautions, connection diagrams, and step-by-step setup procedures. It is intended for users who need to configure or program the controller using the TMCL-IDE software environment. This manual is written in Chinese.
| Supply Voltage | +24V DC or +48V DC nominal (+14.5… +55V DC max.) |
|---|---|
| Motor Current | up to 10A RMS (programmable) peak |
| Microcontroller | ARM Cortex™ -M3 |
| Pre-driver | TMC603A |
| Motor Type | Block commutated 3 phase BLDC motors with optional hall sensors / optional encoder |
| Motor Velocity | up to 100,000 RPM (electrical field) |
| Firmware Version | V2.09 |
| Command Memory | up to 2048 TMCL commands |
It supports RS232 and CAN (2.0B up to 1Mbit/s), RS485 and USB interfaces.
The maximum supply voltage is +55V DC.
It uses a high-performance ARM Cortex™ -M3 microcontroller.
The firmware can be updated by the user and new versions can be downloaded free of charge from the TRINAMIC website.