
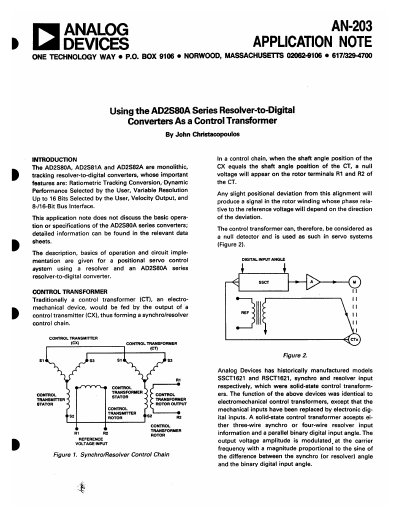
This application note explains how to use the AD2S80A, AD2S81A, and AD2S82A resolver-to-digital converters as control transformers. It details the circuit implementation for a positional servo control system where the converter compares a resolver shaft angle with a parallel binary digital input angle to generate an analog error signal.
| Resolution | Up to 16 Bits |
|---|---|
| Input Data | 16-bit parallel binary data |
| AC Error Output Scaling (10-bit) | 178 mV rms per bit |
| AC Error Output Scaling (12-bit) | 445 mV rms per bit |
| AC Error Output Scaling (14-bit) | 41.125 mV rms per bit |
| AC Error Output Scaling (16-bit) | 2.78 mV rms per bit |
| DC Error Scaling (10-bit) | 160 mV per bit |
| DC Error Scaling (12-bit) | 40 mV per bit |
| DC Error Scaling (14-bit) | 10 mV per bit |
| DC Error Scaling (16-bit) | 2.5 mV per bit |
The ratio multiplier section of the AD2S80A is used independently to perform the function of a control transformer.
It is used to remove any DC offset from the AC error output and to attenuate any high frequency noise induced to the converter.