
A mobile robot autonomous navigation method based on stereo camera and deep learning is proposed in this paper. The method installs a pair of infrared emitters and a pair of infrared receivers on the stereo camera to transmit infrared reflection images to the deep learning model and calculate the distance image of the front ground through the deep learning model. Then the distance image is used as the perception information of the mobile robot and the autonomous navigation algorithm of the mobile robot is used to plan the motion trajectory of the mobile robot to achieve the autonomous navigation of the mobile robot.
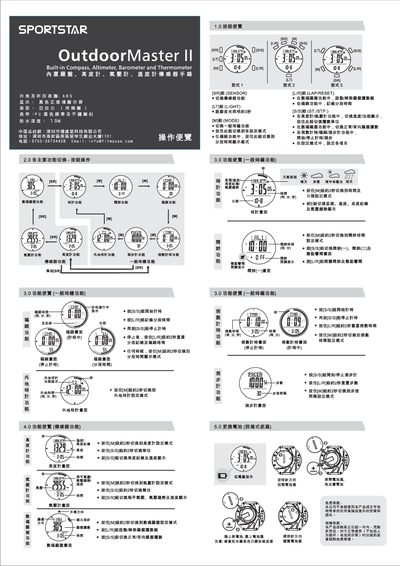
The OutdoorMaster is a multifunction outdoor watch featuring a built‑in compass, altimeter, barometer and thermometer. The manual describes how to switch between these functions, set time and date, and use the step counter and countdown timer.
Key operations include starting and stopping timing, switching display modes by holding the M button, changing altitude units, and replacing the battery. The watch offers a black glass display, PU black strap, and water resistance up to 10 meters. This manual is written in Chinese.
| Water resistance depth | 10 meters |
|---|---|
| Display type | Black glass screen |
| Strap material | PU black strap |
| Case material | Acrylic |