
This document provides detailed information on the features and characteristics of the Accelnet EtherCAT digital servo drive. Accelnet EtherCAT is a high-performance DC powered amplifier for position, velocity, and torque control of brushless and brush motors via EtherCAT, an Ethernet-based fieldbus.
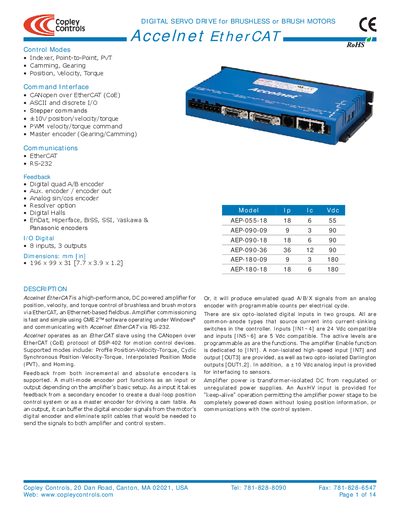
This document describes the Accelnet EtherCAT digital servo drive, a high‑performance, DC‑powered amplifier for position, velocity, and torque control of brushless or brushed motors via EtherCAT. It outlines the supported control modes, communication options, and I/O capabilities.
The manual includes general specifications, detailed wiring diagrams, encoder port functions, digital input/output descriptions, safety protections, mechanical dimensions, and guidance for using CME 2™ software for configuration and commissioning.
| Peak Current (AEP-055-18) | 18 A |
|---|---|
| Continuous Current (AEP-055-18) | 6 A |
| Output Resistance (AEP-055-18) | 0.075 Ω |
| Input Power HV Range (AEP-055-18) | +20 to +55 Vdc |
| PWM Ripple Frequency | 32 kHz |
It supports EtherCAT and RS‑232 communication.
The drive provides eight digital inputs.
The AuxHV input provides a keep‑alive function that allows the power stage to be turned off without losing position information or communication.