
Technical guide for the Leisai DMC-E3032 EtherCAT motion control card, covering hardware, configuration, and example code.
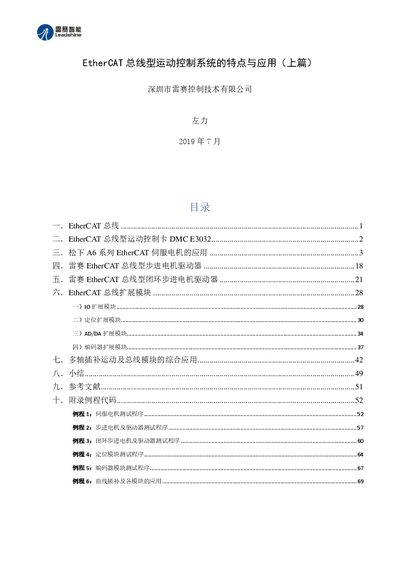
The Leisai DMC-E3032 is an EtherCAT‑based motion control card that can manage up to 32 EtherCAT motors and various expansion modules. It supports multi‑axis point‑to‑point motion, 16‑axis linear interpolation, and 3‑axis circular interpolation, with functions such as hand‑wheel control, encoder position detection, and I/O control.
The manual provides detailed hardware connection diagrams, parameter settings, and example programs in C#, VB.NET, Delphi, and LabVIEW. It also explains EtherCAT bus characteristics, such as a 100 µs refresh cycle and 1 µs clock synchronization accuracy, and includes code for reading/writing positions, speeds, and digital I/O. This manual is written in Chinese.
| Maximum controllable EtherCAT motors | 32 |
|---|---|
| Circular interpolation axes | 3 |
| EtherCAT data refresh cycle | 100 µs |
| Clock synchronization accuracy | 1 µs |
| EtherCAT bus baud rate | 100 Mbps |
The DMC‑E3032 can control up to 32 EtherCAT motors and expansion modules.
Example programs are supplied for C#, VB.NET, Delphi, and LabVIEW.
The EtherCAT bus can refresh data every 100 microseconds.
Node clocks are synchronized with an accuracy of 1 microsecond.