
User manual for the Googol GSN series motion controller covering structure, installation, wiring, debugging, electrical parameters and troubleshooting.
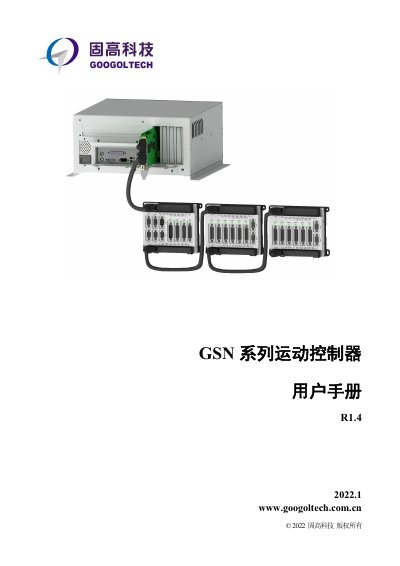
This user manual from Googol Technology (固高科技) describes the GSN series motion controller, which performs high-speed point-to-point motion control using a dedicated high-performance processor. The controller uses a host computer via a standard PCI-E bus interface and provides C language function libraries and Windows dynamic link libraries, so users can integrate the control functions into their own application programs. The manual is intended for engineers with basic hardware knowledge and some understanding of control, and C language or Windows DLL programming experience is required to use the controller.
The manual consists of three chapters covering the controller's composition, model numbering (main card, axis modules and communication cables), product outline drawings, function descriptions, quick-start installation steps, software debugging, and indexes. It also lists related documents such as the GXM series terminal board module user manual and the GXN series programming manuals. This manual is written in Chinese.
| Servo control period | 250 us |
|---|---|
| Control period | 250 us |
| Analog output/input range | -10V~+10V, 16-bit DAC |
| Encoder input | Quadrature incremental, max 8 MHz (after quadrupling) |
| Limit signal input | 1 positive/negative limit per axis, optocoupler isolated, with soft limit |
| Position compare output | 24V/5V |
| Main card processor | Dual-core dedicated processor (core1/core2) |
| Max supported axes (GSN-064) | 64 axes |
It is used in a wide range of fields including robots, CNC machine tools, woodworking machinery, printing machinery, assembly lines, electronic processing equipment, laser processing equipment and PCB drilling/milling equipment.
Users need C language programming experience or experience using dynamic link libraries under Windows.
Connect the main card's gLink-IIA port to the first terminal board; for a ring (redundant) network, connect the last module's free port to the main card's gLink-IIB to form a closed-loop topology.
When first using the board, disconnect the motor from the load and do not connect it to any mechanical device until the control system is installed and debugged and the motor is under control.