
This document describes the functions of the DMC600M controller, including motion control, limit functions, IO interfaces, and parameter details.
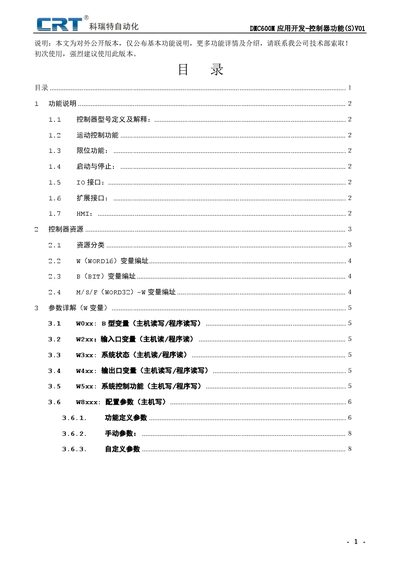
This manual provides an overview of the DMC600M motion controller, covering its model definition, motion control capabilities (XYZ/UVW axes, interpolation), limit functions, start/stop logic, and IO/extension interfaces. It details the controller's resources, including W, B, M, S, and F variable addressing schemes. This manual is written in Chinese.
| Axes Control | XYZ, UVW six-axis control |
|---|---|
| Interpolation | XYZ three-axis linear, UV three-axis linear, XY arc, UV arc |
| IO Inputs | 8 general-purpose inputs (expandable to 48) |
| IO Outputs | 8 general-purpose outputs (expandable to 32) |
| Flash Storage | Up to 128 user programs, max 2500 instructions per program |
| Parameter Storage | Up to 512 pages, 16384 parameters per page |
It belongs to the DMC6 series, which is expected to expand to models like DMC630M, DMC640M, DMC650M, and DMC660M.
Yes, the M-type product supports the Modbus protocol.
It supports control of six axes: X, Y, Z, U, V, and W.