
This user manual covers the installation, wiring, and debugging of the BWSensing BW-IMU127 series low-cost Modbus inertial measurement unit.
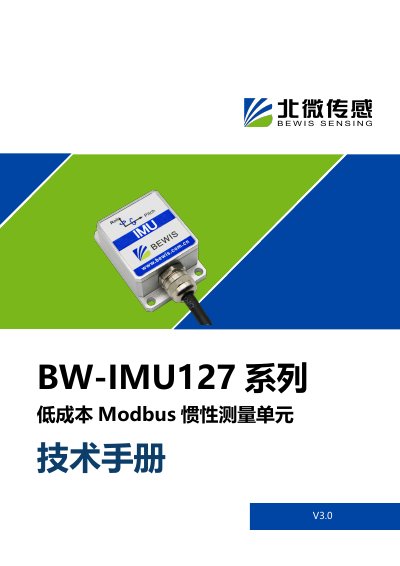
The BWSensing BW-IMU127 is a high-precision strapdown inertial measurement unit designed to measure angular velocity and acceleration parameters. It utilizes MEMS accelerometers and gyroscopes with algorithms such as 6-state Kalman filtering, nonlinear compensation, orthogonal compensation, temperature compensation, and drift compensation to ensure accuracy in motion or vibration states. The device features digital interfaces (RS232/485/TTL) for easy integration into user systems. This manual is written in Chinese.
| Operating Voltage | 9-35VDC |
|---|---|
| Working Current | 30mA (40mA max) |
| Operating Temperature | -40~85℃ |
| Storage Temperature | -55~100℃ |
| Gyroscope Resolution | 0.01°/sec |
| Gyroscope Range | ±400°/sec |
| Zero Bias Stability (100s, 1σ) | <2°/h |
| Bandwidth | 100Hz |
| Accelerometer Range (X,Y,Z) | 2g |
| IP Rating | IP67 |
The unit supports RS232, RS485, and TTL interface outputs.
The packaged product measures 55mm x 37mm x 24mm (LxWxH).
The installation surface must be tightly fixed and flat against the measured surface, ensuring no angle between them.