
The utility model discloses an intelligent robot arm for a magnetic particle chemiluminescence immunoassay analyzer, comprising a robot arm Z-direction motion module and an X-direction motion cup strip gripper module, wherein the X-direction motion cup strip gripper module comprises an X-direction linear motor, and the X-direction linear motor controls the connecting slider to drive the gripper fingers to move, The X-direction motion cup strip gripper module includes a cup strip detection device and a tray detection device, the cup strip detection device is internally provided with a light source发射板, the light source发射板上 is provided with a light source reflection detector, the tray detection device is provided with a photoelectric switch and a grating 片。
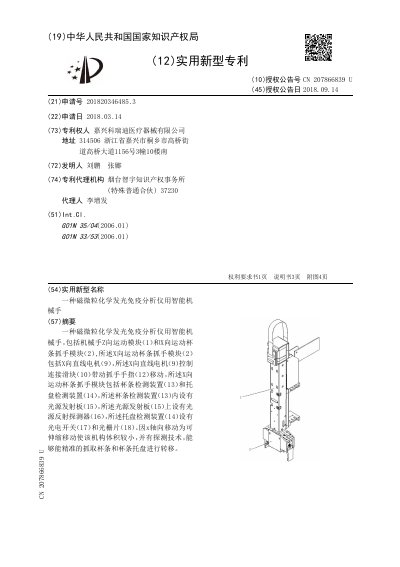
This Chinese utility model patent from Jiaxing Keruidi Medical Device discloses an intelligent robot arm for magnetic particle chemiluminescence immunoassay analyzers. It integrates a Z-axis motion module and an X-axis motion cuvette gripper module for automated sample transfer.
The Z-axis uses a linear stepper motor for smooth, high-precision movement, while the X-axis uses a dual-output-shaft linear stepper motor to control gripper fingers. Cuvette and tray detection devices with photoelectric switches and grating plates help prevent empty or multiple grabs during transfer. This manual is written in Chinese.
| Z-axis drive motor | linear stepper motor |
|---|---|
| X-axis linear motor | dual-output-shaft linear stepper motor |
| Z-axis motion | smooth and high precision |
| X-axis movement | telescopic and compact |
It includes a Z-axis motion module and an X-axis motion cuvette gripper module.
Cuvette detection uses a light source emission plate and reflective detector, while tray detection uses a photoelectric switch and grating plate.
It makes the mechanism smaller in volume and enables precise grabbing and transfer of cuvettes and trays.