
This is a DC motor manual, which contains parameters such as motor power, voltage, speed, torque, current, encoder type, encoder resolution, weight, diameter, and shaft diameter.
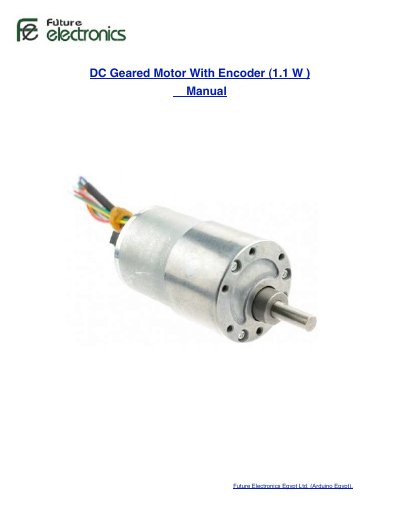
This manual from Future Electronics Egypt Ltd. (Arduino Egypt) describes a 12 VDC geared motor with an output power of 1.1 W and a Hall effect quadrature encoder mounted on the rear motor shaft. It lists the motor and encoder specifications for the 1:20 and 1:60 gear ratios, including rated speed, torque, current, encoder resolution, weight and dimensions.
The document explains how the quadrature encoder works and how its two channels (A and B) are used, shows the pin connection, and describes the three options for connecting the encoder signals to interrupt or non-interrupt pins. It also covers measuring position and RPM, detecting the direction of rotation, an example schematic and source code for connecting to a PIC microcontroller, and a note on using external interrupts.
| Voltage | 12 VDC |
|---|---|
| Output Power | 1.1 W |
| Gear Ratio | 1:20 or 1:60 |
| Rated Speed | 185 RPM (gear ratio 1:20); 58 RPM (gear ratio 1:60) |
| Rated Torque | 7.84 N.cm (gear ratio 1:20); 25.4 N.cm (gear ratio 1:60) |
| Rated Current | 0.41 A |
| Encoder Type | Hall effect quadrature encoder, 5 V |
| Encoder Resolution | 60 counts per revolution |
| Encoder Operating Voltage | 4.5 V to 5.5 V |
| Weight | 160 g |
| Diameter | 37 mm |
| Shaft Diameter | 5.5 mm |
The encoder gives 60 counts per main shaft revolution with the 1:20 gear ratio and 180 counts per main shaft revolution with the 1:60 gear ratio.
The motor is rated for 12 VDC, while the encoder operates from 4.5 V to 5.5 V.
Connect both signals, channel A and channel B, to interrupt pins (pins 2 and 3 on an Arduino Uno).
It is done by comparing the old readings from pin A and pin B with the new readings from pin A and pin B.