
This is a uni-polar stepper motor driver that provides a convenient way of controlling standard Uni-Polar stepper motors rated at up to 5A and 24V DC in one of two modes.
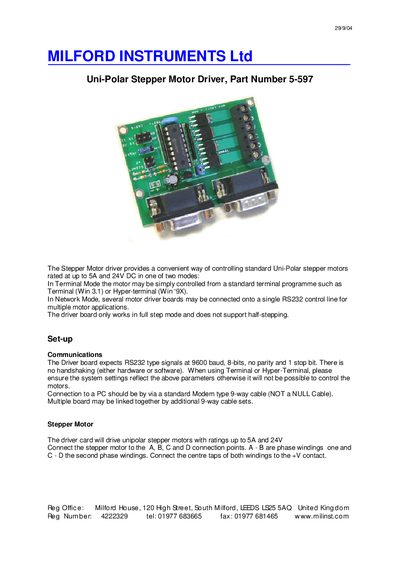
The Uni-Polar Stepper Motor Driver 5-597 controls standard unipolar stepper motors up to 5 A and 24 V DC. It operates in either Terminal mode, using a PC terminal program, or Network mode, allowing multiple driver boards on a single RS‑232 line. The driver expects RS‑232 signals at 9600 baud, 8‑N‑1 with no handshaking.
The manual details power‑supply connections, jumper settings for mode and address selection, limit‑switch wiring, command formats for both terminal and network modes, and the accompanying Windows software for scripting motor movements. It also explains timeout handling and provides a full list of scripting commands.
| RS‑232 parameters | 9600 baud, 8‑bits, no parity, 1 stop bit, no handshaking |
|---|---|
| Power‑supply voltage range | 7.5 V to 15 V DC (shared) or separate 9 V supply |
| Maximum step count per command | 65536 steps |
| Step delay range | 2 ms to 255 ms |
Set jumper 3 to the NET position.
Use 9600 baud, 8 data bits, no parity, 1 stop bit, and no handshaking.
Remove the J5 jumper and connect a separate 9 V supply to the –/+ pads on the board.
Send a 4‑byte command where bits 3/5 are 011 for forward with limits active.