
E-ZEUS is a universal motor drive device developed by amateur enthusiasts. It overcomes all the shortcomings of stepping motor and micro-step driving, such as vibration and shaking during sidereal operation, and fine decoupling during high-speed slow-up rotation, which leads to poor accuracy of automatic guiding. Due to the low price, simple parts, but high value.
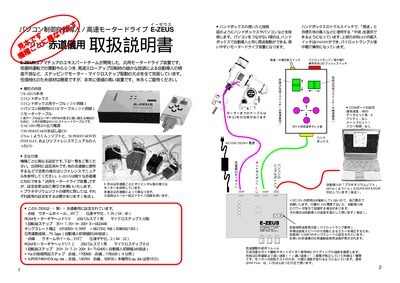
This manual provides instructions for installing and operating the E‑ZEUS motor drive, a universal drive unit for equatorial telescope mounts. It covers power connections, handbox controls, and software setup for automatic tracking and guiding.
The guide details how to connect the handbox, RS‑232C cable, and optional auto‑guider, explains speed adjustments via the high/low toggle and internal volume knobs, and offers tips for using the device with different power sources and correcting tracking errors. This manual is written in Japanese.
| Gear ratio | 1.35 (54:40) |
|---|---|
| Steps per revolution (RA) | 6 823 440 |
| Steps per revolution (Dec) | 7 142 400 |
| Power supply (output) | 24 V DC |
Use the toggle switch on the handbox; the high‑speed position enables fast auto‑tracking, while the low‑speed position is used for guiding.
Connect the auto‑guider via the 6‑pin modular connector using the pinout: RA+ (W), DBC+ (⑤), DBC‑ (N), RA‑ (B), GND, GND.