
This manual provides simplified instructions for wiring and debugging Yongbo servo drives, covering power connections, signal wiring, encoder setup, and…
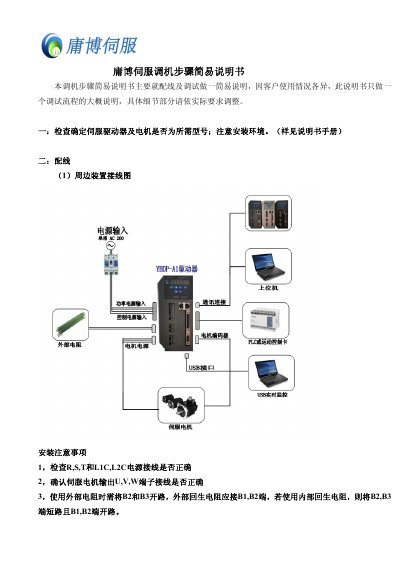
This document serves as a simplified guide for the commissioning of Yongbo servo drives. It outlines general procedures for verifying equipment models, checking installation environments, and performing initial checks on power and motor output wiring.
The manual details specific wiring configurations for peripheral devices, signal connections based on control modes (position, velocity, torque), and encoder interface setups for different motor power ratings. It also explains how to configure key parameters such as rotation direction, control mode selection, pulse input formats, analog gain settings, and electronic gear ratios. This manual is written in Chinese.
| Encoder Wire Gauge | 0.13mm (26AWG) |
|---|---|
| Wire Type Standard | UL2464 |
| DI/DO Power Requirement | 12V — 24V |
The default value is 0010.
They should be connected to terminals B1 and B2, with B2 and B3 left open.