This manual covers the electrical operation, maintenance, and servo drive fault code troubleshooting for the HSR-BR612-CIII industrial robot.
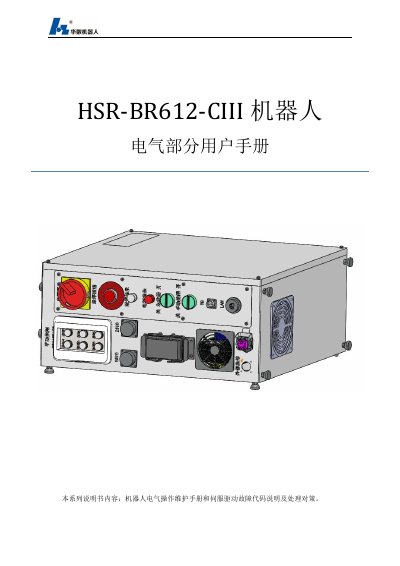
This document serves as a user guide for the HSR-BR612-CIII industrial robot, detailing the electrical components, system layout, and safety protocols required for operation and maintenance. It is authorized and organized by Foshan Huashu Robotics Co., Ltd. to assist users in safely learning and using the equipment.
The manual provides comprehensive instructions on safety precautions, including specific guidelines for debugging, automatic operation, and electrical usage. It also describes the robot's control system components, such as the IPC controller, servo drivers, and EtherCAT bus loops, along with troubleshooting guides for controller alarms and servo drive fault codes. This manual is written in Chinese.
Maintenance must be performed by a team of two people, with one person ready to press the emergency stop button and the other performing the task.
You must press the emergency stop button and cut the power to ensure the robot cannot move.
The load must be controlled within the allowable lifting weight specified for the robot.