
The CUAV V5 nano autopilot user manual provides interface definitions, hardware specs, safety certifications, and usage precautions.
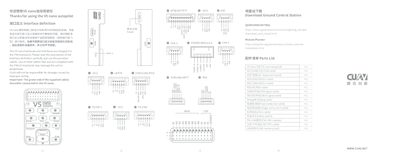
This manual introduces the V5 nano autopilot, detailing its hardware interfaces, connector pinouts, and recommended cabling. It emphasizes using the supplied green‑ended cables and following the PX4 standard to avoid damage.
The document also lists the main processor, sensor suite, power requirements, dimensions, and certifications, and it outlines safety rules for operating UAVs with the autopilot, such as flight height limits and no‑fly zones. This manual is written in Chinese.
| Main Processor | STM32F765 (32‑bit Arm Cortex‑M7, 216 MHz, 2 MB flash, 512 KB RAM) |
|---|---|
| Firmware | PX4 / Ardupilot |
| Supported Vehicles | Multi‑rotor, fixed‑wing, helicopter, VTOL, unmanned boat, unmanned car |
| Accelerometer | ICM‑20602, ICM‑20689, BMI055 |
| Gyroscope | ICM‑20602, ICM‑20689, BMI055 |
| Magnetometer | IST8310 |
| Barometer | MS5611 |
| Power Input Voltage | 4.5 V – 5.5 V |
| Operating Temperature | -40 °C – 85 °C |
| Size | 40 × 60 × 17.8 mm |
| Weight | 41 g |
Do not fly in no‑fly zones, keep flight height below 120 m, stay at least 8 km from airports, avoid flying over people, houses, vehicles, or venues, and do not fly in rain, strong wind, or fog.