
This document is the user manual of Victor SPX, which introduces the features and usage methods of Victor SPX
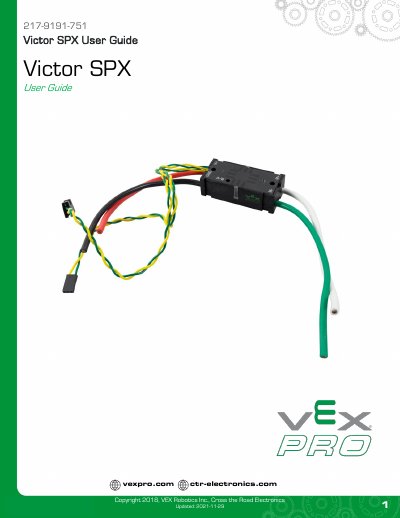
The Victor SPX is a speed controller designed through collaboration between VEX Robotics and Cross the Road Electronics. It is intended for fine control and high performance of brushed DC motors in competition robotics applications and handles high current loads with minimal voltage drop and heat generation.
The guide covers the Victor SPX specifications, wiring the input and output, CAN bus and PWM control, mounting, strain relief, first power-up, brake and coast modes, calibration, blink codes, thermal performance, FAQs, and troubleshooting.
| Outside Dimensions | 2.50” x 1.16” x 0.77” [63.5mm x 29.5mm x 19.5mm] |
|---|---|
| Weight (Without Wire) | 0.20 lbf [0.09 kgf] |
| Nominal Voltage | 12 V DC |
| Min/Max Voltage | 6-16 V DC |
| Continuous Current | 60A |
| Surge Current (2 sec) | 100A |
| PWM Input Pulse (High Time) | 1 – 2 ms |
| PWM Output Chop Rate (Switching Frequency) | 15.625 kHz |
| Minimum Throttle (Deadband) | Adjustable [0.1% - 25% (4% Default) ] |
It is a speed controller designed through collaboration between VEX Robotics and Cross the Road Electronics.
The nominal voltage is 12 V DC.
A 40A or smaller breaker should be used in series with the positive input.