
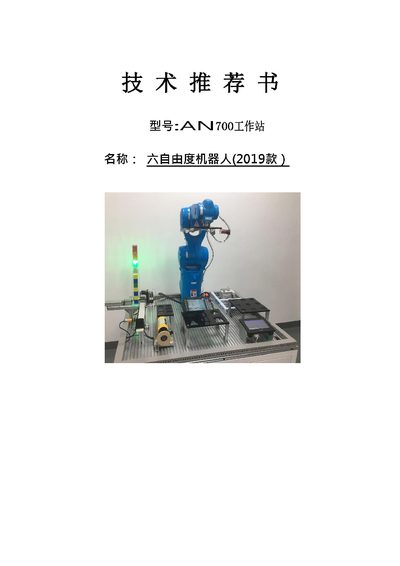
The AN700 is a compact six‑axis robot designed for university teaching and small‑scale industrial tasks. It features six stepper motors with harmonic gear reducers, a 15‑bit absolute encoder, and supports Modbus RTU communication. The robot’s lightweight aluminum structure provides high speed, precision and stability, with a maximum payload of up to 6 kg and a reach of about 1300 mm.
The manual includes system overviews, hardware interfaces, programming rules, and communication details. It provides wiring diagrams for power and signal connections, describes the controller’s port definitions, and lists supported motion control commands and file formats for robot operation. This manual is written in Chinese.
| Encoder resolution | 15‑bit absolute, 32768 pulses |
|---|---|
| Power supply | 24 VDC ±10 % |
| Rated speed | 1000 RPM |
| Maximum speed | 1500 RPM |
| Maximum payload | 6 kg |
| Reach | 1300 mm |
| Communication protocol | Modbus RTU 19200,8N1 |
The robot can handle a maximum load of 6 kg.
It uses Modbus RTU with a baud rate of 19200, 8‑N‑1 configuration.
The robot uses a 15‑bit absolute encoder providing up to 32768 pulses.
It requires a 24 VDC supply with a tolerance of ±10 %.