
Sensorless Vector Control Techniques for Ultraefficient Motor Control
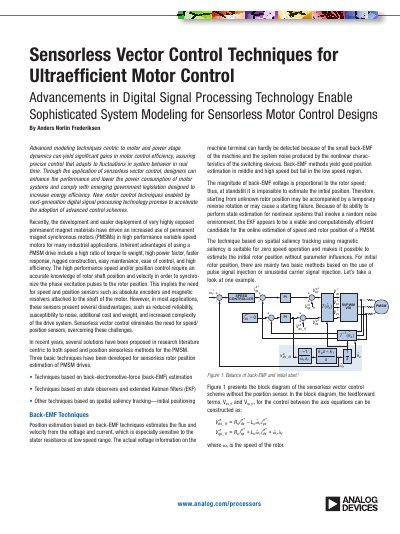
The document explains how advancements in digital signal processing technology enable sophisticated system modeling for sensorless motor control designs. It details three basic techniques for estimating rotor position without sensors: back-electromotive-force (back-EMF) estimation, state observers and extended Kalman filters (EKF), and spatial saliency tracking.
This technique eliminates the need for speed and position sensors, which reduces system cost, weight, and complexity while improving reliability.
These methods fail in the low speed region because the actual voltage information on the machine terminal is hard to detect due to small back-EMF and system noise.
The EKF uses a nonlinear dynamic state model in a stationary reference frame attached to the stator, making it independent of the rotor position for estimation.