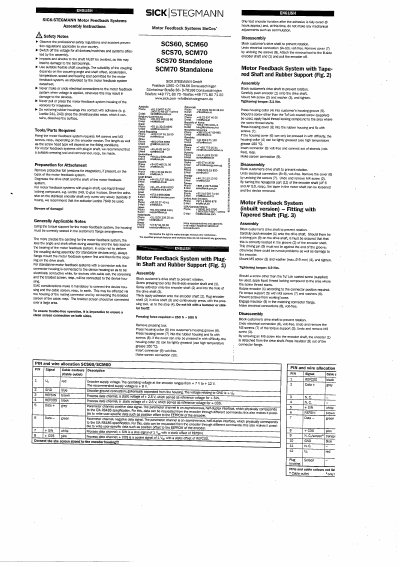
This document provides assembly and disassembly instructions for SICK STEGMANN Motor Feedback Systems, specifically models SCS60, SCM60, SCS70, and SCM70. It covers three mounting configurations: systems with a plug-in shaft and rubber support, systems with a threaded shaft and rubber support, and inbuilt versions with a tapered shaft. The guide details safety precautions, required tools, and specific steps for attaching and removing the encoder from the drive shaft.
| Operating voltage range | + 7 V to +12 V |
|---|---|
| Recommended supply voltage | + 8 V |
| Reference voltage for + SIN | + 2.5 V |
| Reference voltage for + COS | + 2.5 V |
| + SIN signal amplitude | 4 Vp |
| Tightening torque (Threaded shaft) | 3.1 Nm |
| Tightening torque (Tapered shaft) | 4.9 Nm |
| Pressing force required | 250 N ~ 500 N |
M4 screws and M3 screws are required, depending on the encoder version, along with suitable flexible shaft couplings.
The adhesive on the stainless encoder shaft typically cures in about 8 hours.
The tightening torque for the threaded shaft version is 3.1 Nm.