
InnoBot user manual, introduces the assembly method, component list, module set components, using tools, circuit connection diagram and other contents of InnoBot.
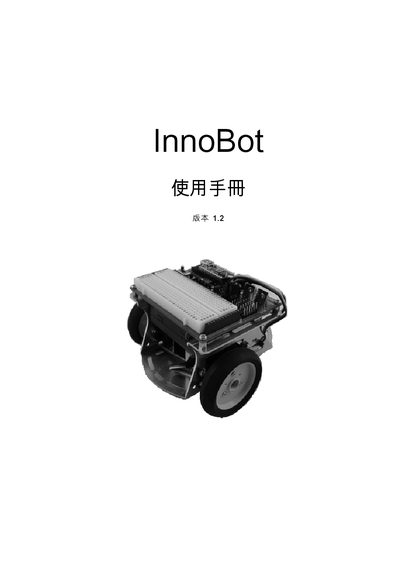
This manual guides users through assembling the InnoBot robot, including a detailed parts list, required tools, and step‑by‑step instructions for mounting the servo, battery, and education board. Safety notices and warranty information are also included.
In addition to mechanical assembly, the document explains how to program the robot using the BASIC Commander language, covering commands such as SOUND, pulse output, and sensor handling, as well as voltage‑dependent performance specifications for the servo motor. This manual is written in Chinese.
| Size (L×W×H) | 39.S×20.0×35.6 mm |
|---|---|
| Servo speed at 4.8 V | 0.15 s per 60° |
| Servo speed at 6.0 V | 0.13 s per 60° |
| Force at 4.8 V | 2.5 cm |
| Force at 6.0 V | 2.8 cm |
The robot measures approximately 39.S mm × 20.0 mm × 35.6 mm and weighs 42 g.
Use the SOUND command with the syntax "SOUND Pin, Duration, Frequency" to generate tones of the desired frequency and length.